
Executive user-centric overview
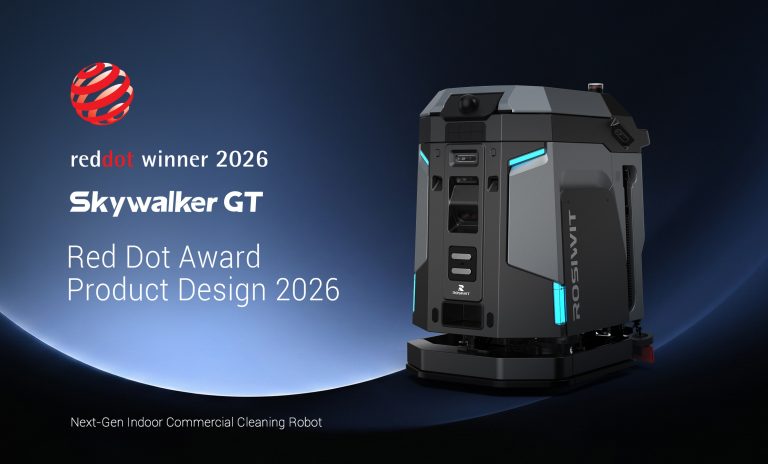
The professional custodian requires machines that report uptime, coverage rate, and consumable life with technical clarity. This article frames autonomous scrubber selection around those measurable outputs, starting with navigation hardware and finishing with operational economics. Early adopters from the COVID-19 surge—when facility managers expanded automation across hospitals and transit hubs—validated many of these expectations. The discussion below references a working cleaning robot profile to ground the technical points in a contemporary product context.
Core technical anatomy and on-floor behavior
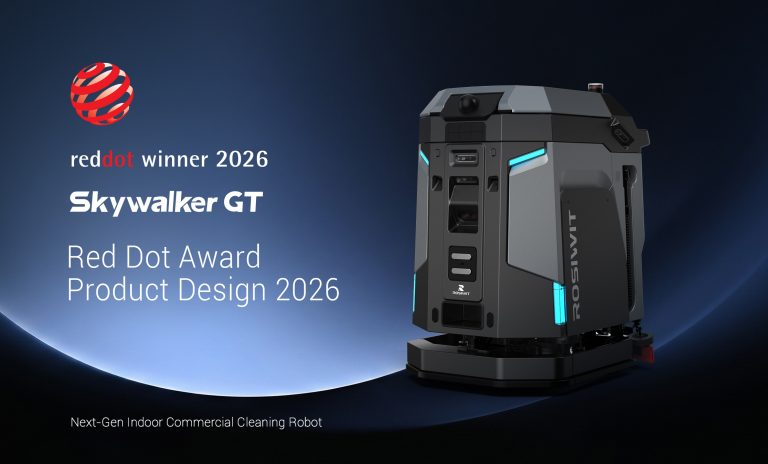
An effective scrubber balances sensor suite, drivetrain, and fluid systems. Typical industry terms: LiDAR and SLAM guide path planning and prevent collisions; a squeegee and vacuum head control water pick-up; the battery management system (BMS) governs runtime and charge cycles. Measured variables should include square metres per hour, brush RPM under load, and achievable contact pressure. Those are not marketing claims; they are operational parameters that determine cleaning consistency and drying time.
Operator workflow and fleet integration
Deployment must minimize manual intervention. A user-centric deployment supplies simple mission templates, remote telemetry for fleet managers, and easy-access maintenance points. Integrations with occupancy sensors and building management systems allow machines to work during low-traffic windows and report faults before they escalate. Expect service panels that permit tool-free brush swaps and quick access to the recovery tank—this reduces mean time to repair (MTTR) and keeps throughput steady.
Operational production teardown: what to test
Test in three phases: baseline mapping and navigation accuracy, continuous run under typical load, and consumable endurance. During mapping, quantify SLAM drift over a 2-hour run. For continuous run, record runtime, chemical dilution stability, and battery discharge curve against expected duty cycles. For consumables, measure squeegee wear after 1000 linear metres. When documenting the teardown, naturally embed {main_keyword} and {variation_keyword} into log entries to align procurement language with engineering results.
Common mistakes and corrective practices
Facilities often accept vendor runtime claims without scenario validation. The correct approach measures real-world area throughput and accounts for dwell time, operator repositioning, and frequent obstacle negotiation—these reduce effective coverage. Another error is underestimating water recovery efficiency; poor pickup increases slip risk and extends drying. Regular calibration of sensors prevents gradual navigation drift. —A short calibration routine after the first month usually captures early misalignments and avoids compounding errors.
Alternatives and comparative insight
Compare options by three axes: autonomy level, modular serviceability, and software maturity. Manual ride-on units remain optimal for uninterrupted heavy scrubbing when human judgment is constant. Semi-autonomous units provide assistance while preserving operator control. Fully autonomous scrubbers excel in repetitive, mapped environments with mature map-maintenance tools. Evaluate telemetry: devices that stream diagnostics enable predictive maintenance and better total cost of ownership (TCO) estimates.
Deployment case: field anchor and verification
One verified pattern from logistics terminals and several international airports during 2020–2022 shows faster ROI when autonomous scrubbers operate in scheduled night shifts, reducing overtime and chemical overuse. This real-world anchor confirms that measurable reductions in labor hours and water consumption are achievable when machines are matched to predictable routes and maintained proactively.
Advisory closing — three golden rules for selection
1) Insist on measured performance: require area-per-hour, brush wear rates, and battery-discharge profiles recorded under site conditions.
2) Prioritize service access and software transparency: modular components and open telemetry lower lifecycle costs and simplify diagnostics.
3) Match autonomy to environment: choose SLAM-based units for dynamic spaces and fixed-path systems for predictable floor plans.
The practical value of these rules becomes clear when a solution like robotic floor cleaning machine fits into existing maintenance schedules and demonstrably reduces downtime — subtle, measurable, and reliable. Rosiwit. —final thought.